Development of Smart Rescue System for Great Deep Railway Facilities
South Korean Government-Funded R&D Initiative · CORNERS Project
Project Overview
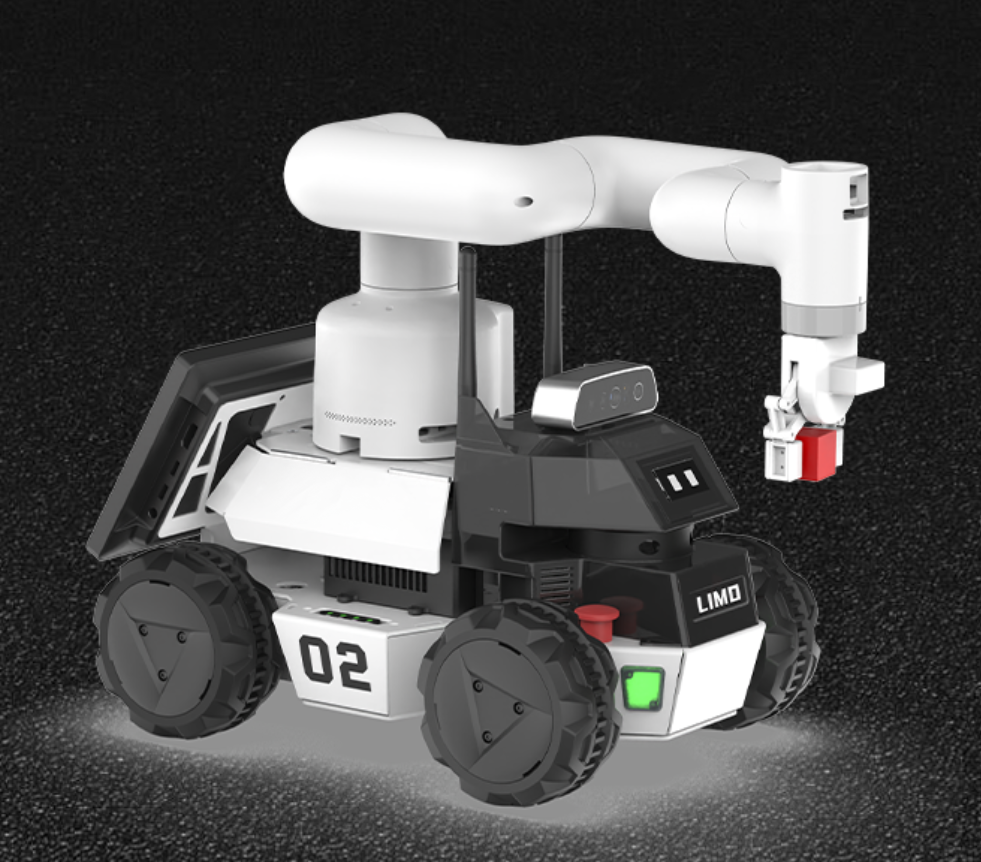
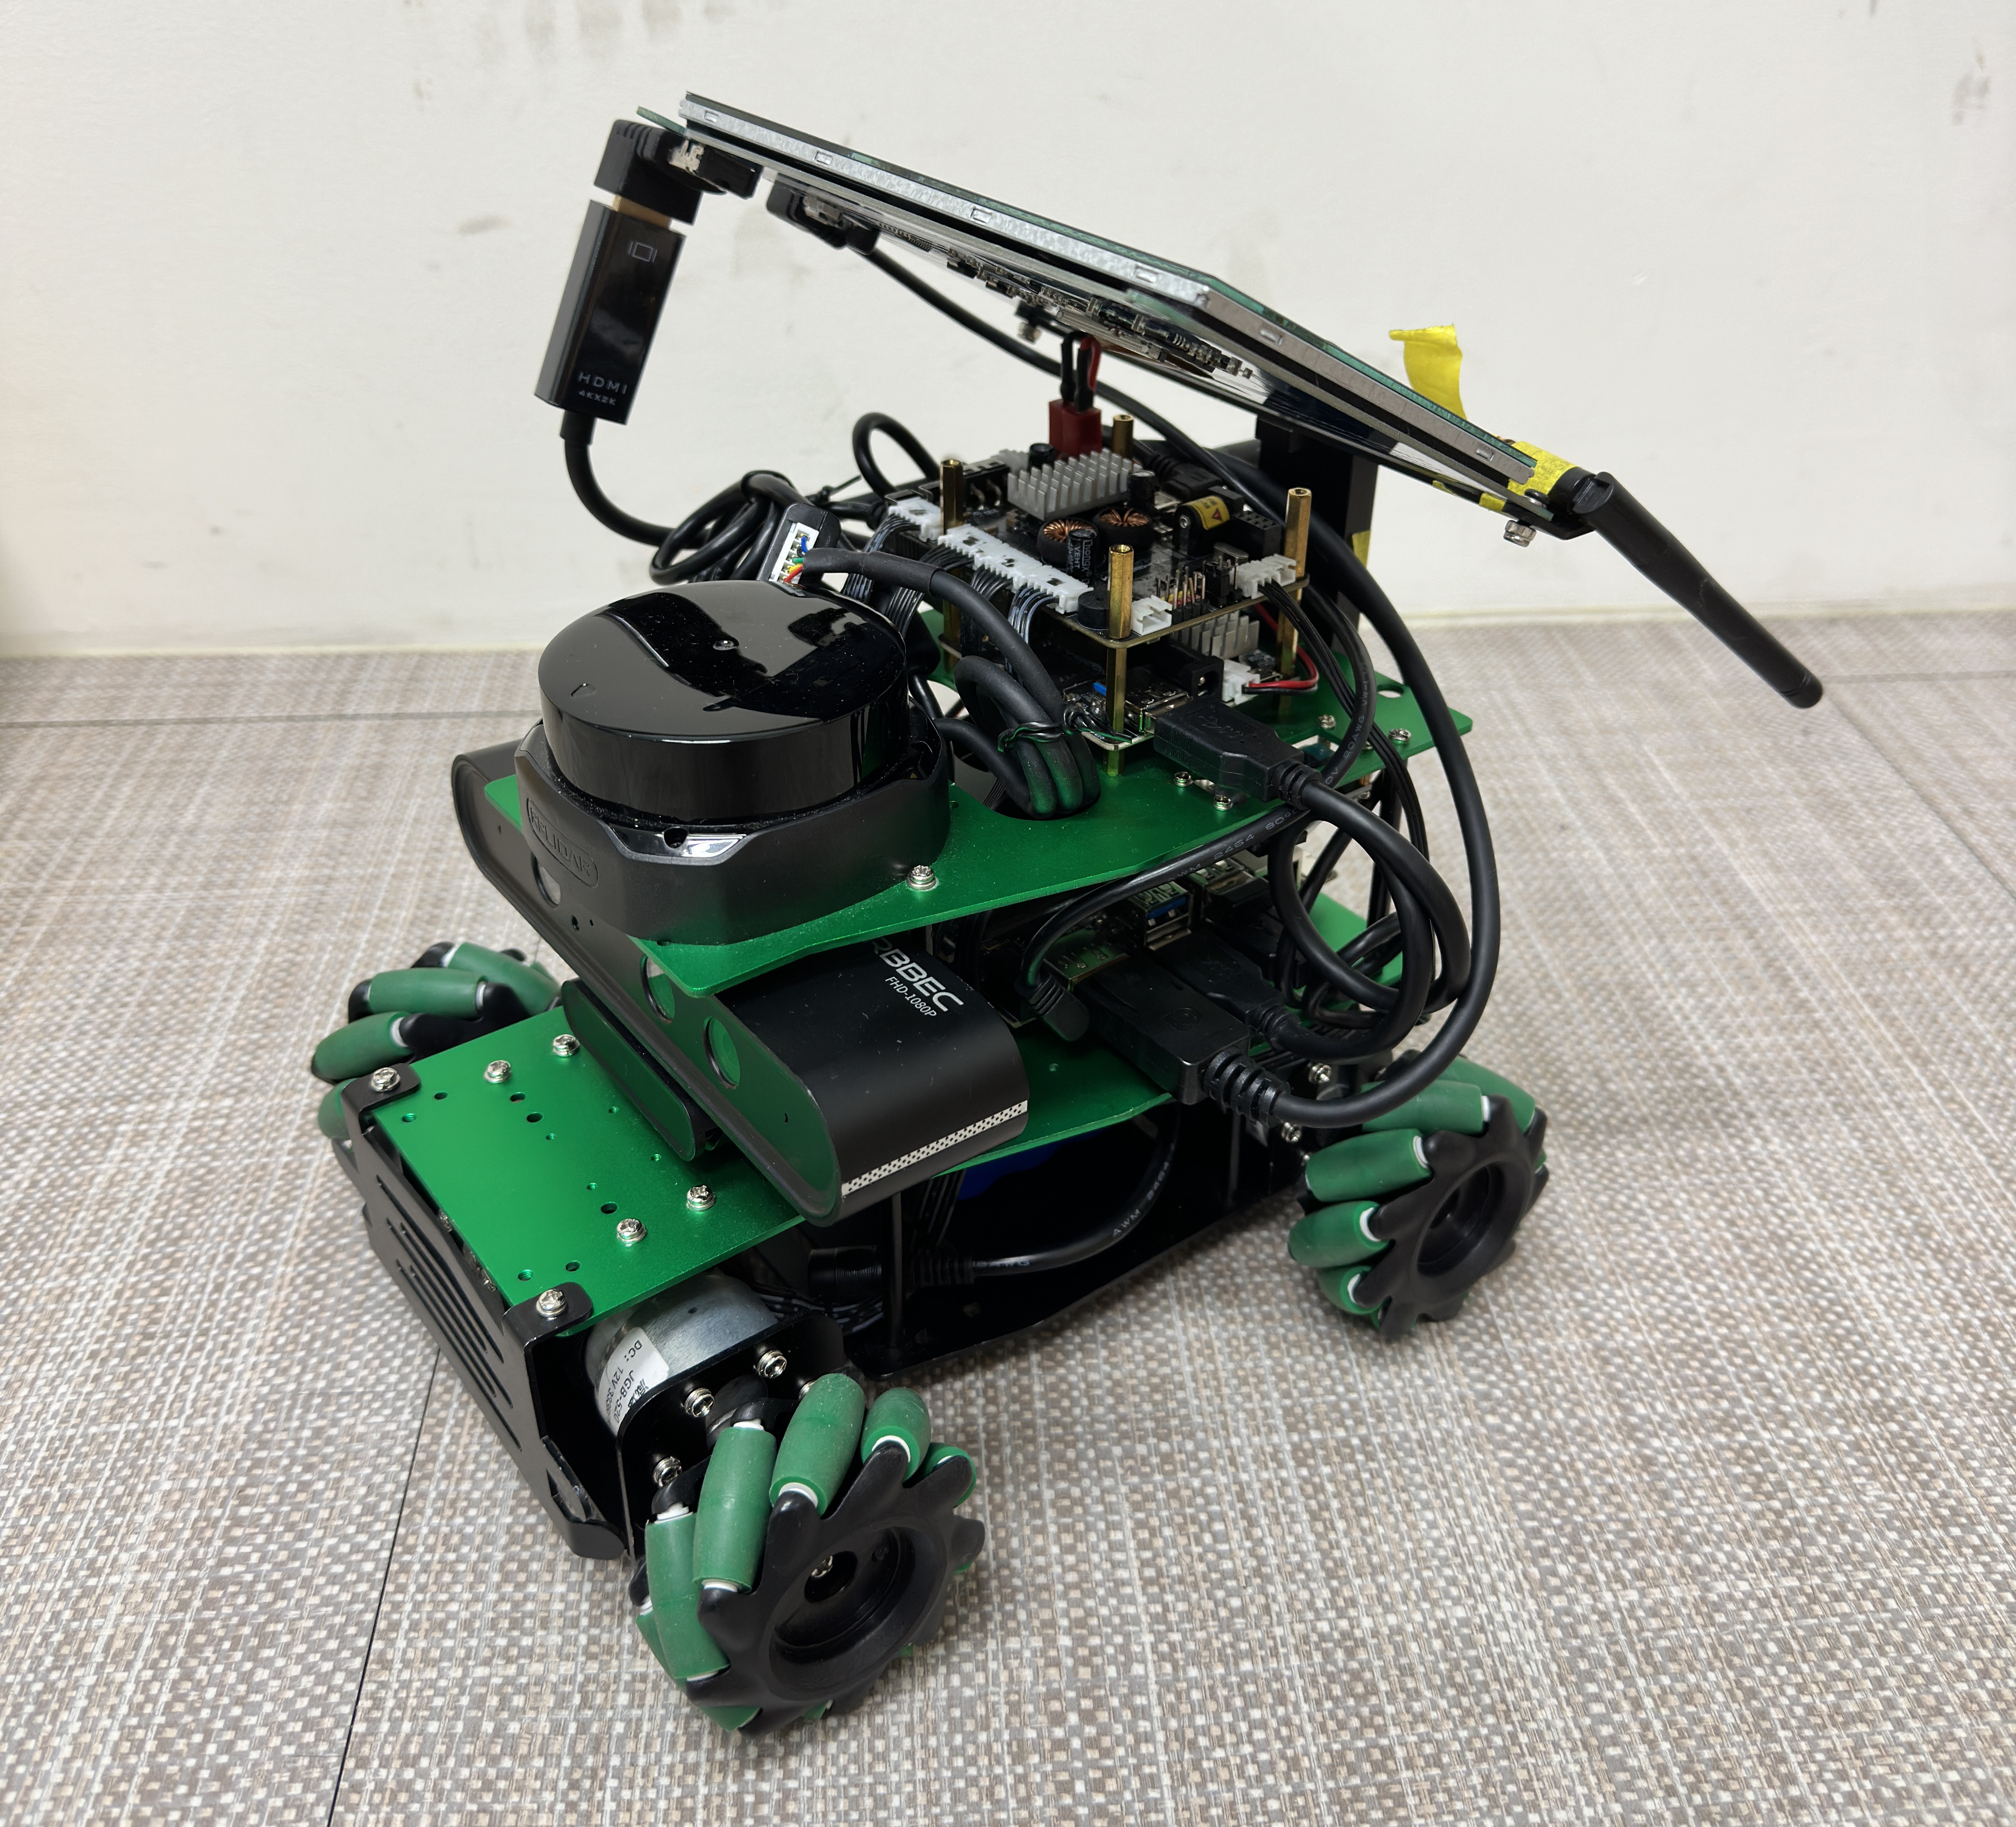
Team Collaboration — Localization & Digital Twin Synchronization
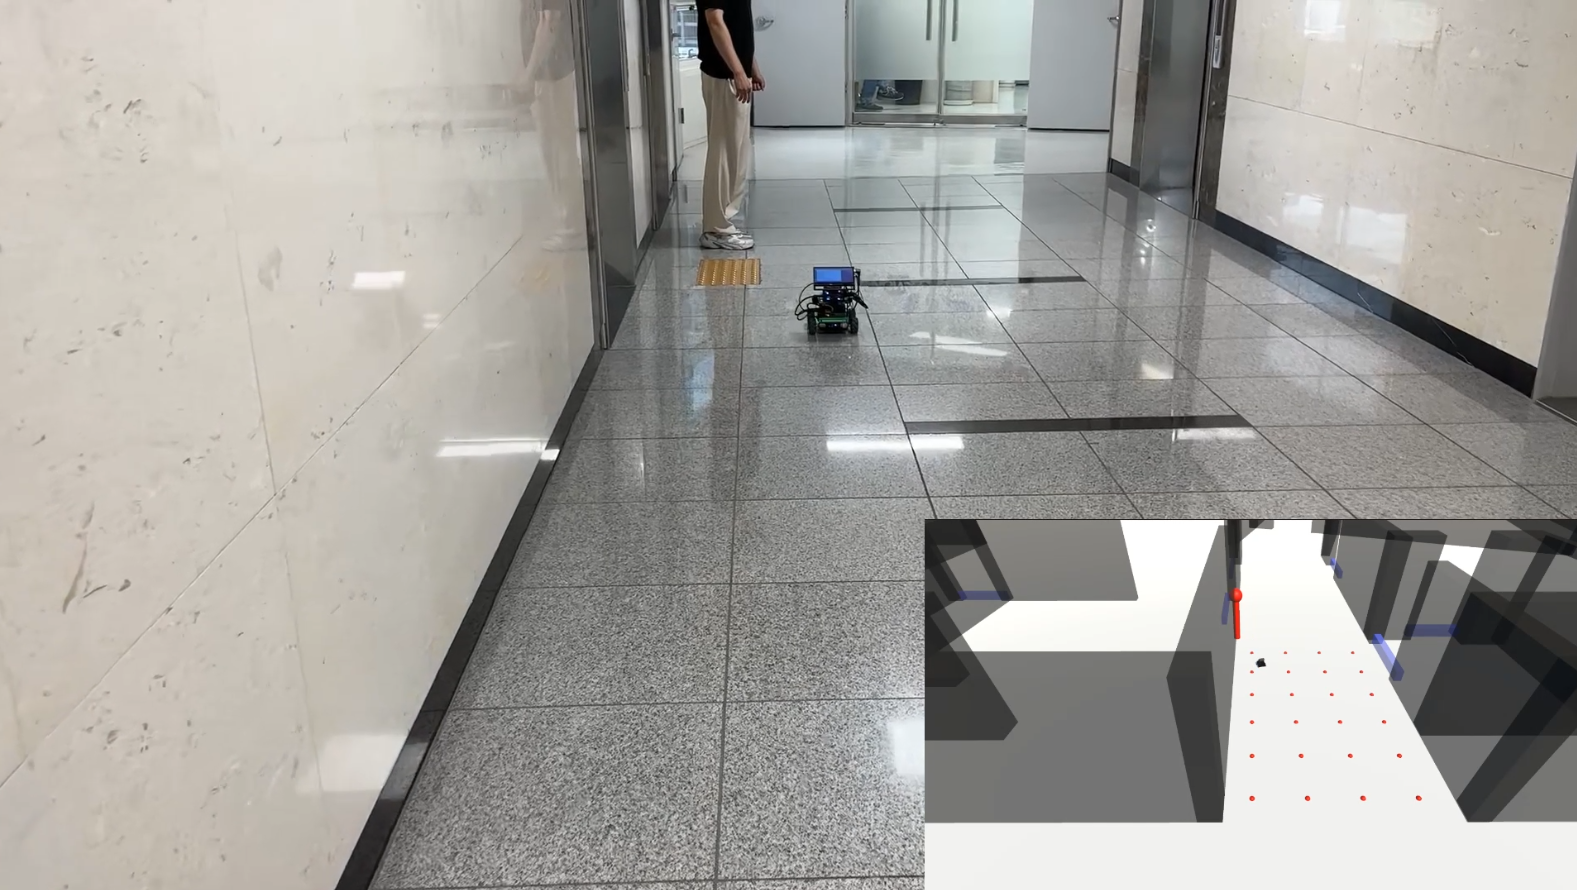
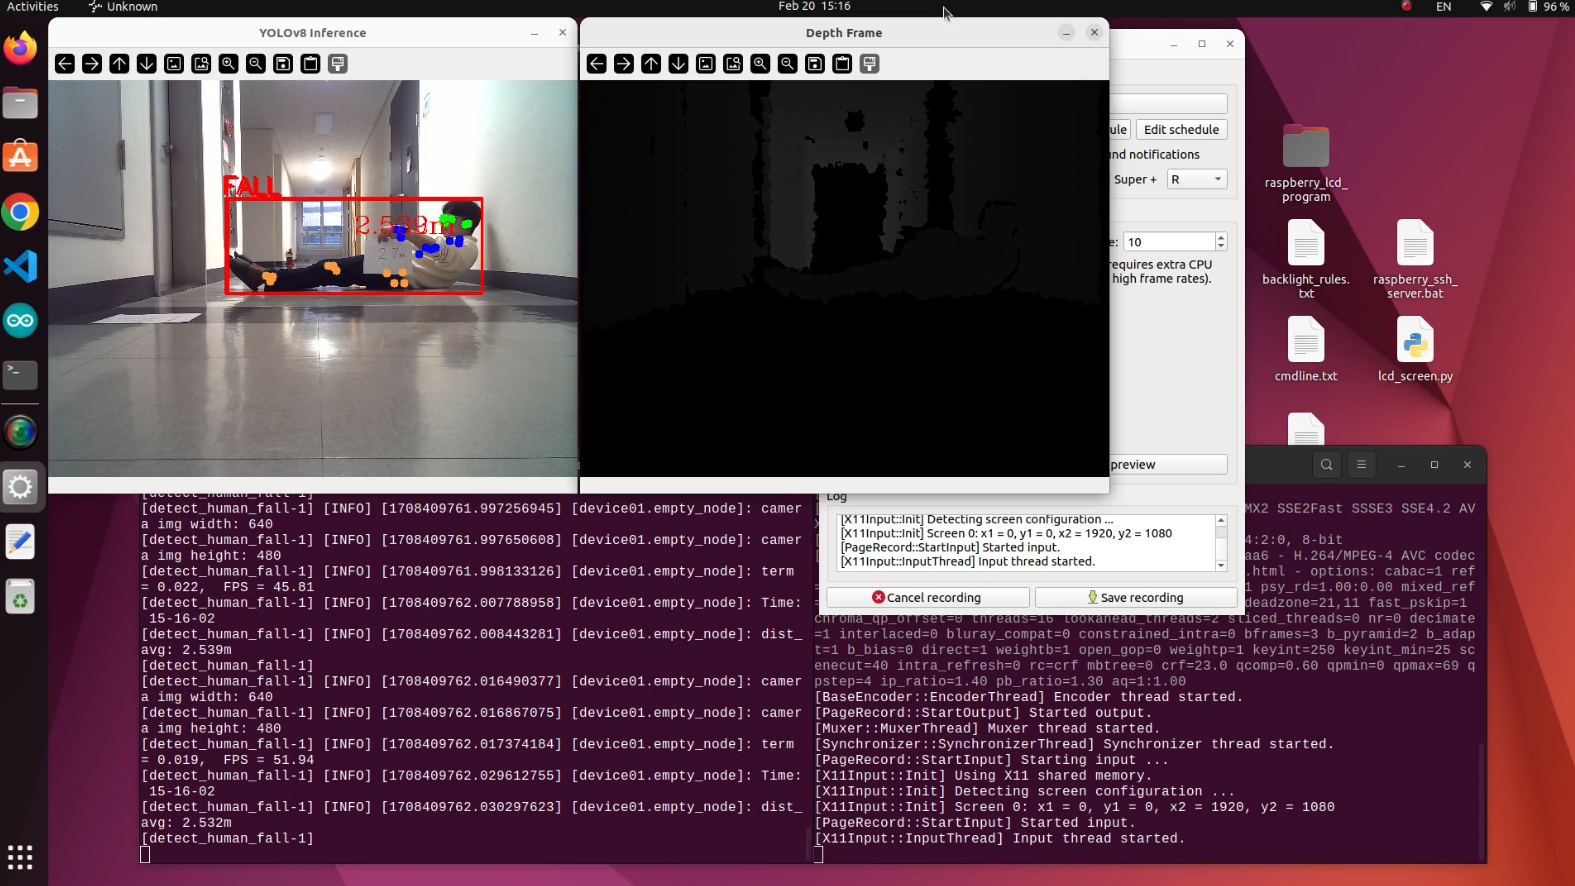
A real-world localization and synchronization test was conducted in a company corridor. In collaboration with a Unity engineer, the corridor environment was reconstructed as a 3D model in Unity and synchronized with a physical mobile robot in real time.
The robot first performed LiDAR SLAM-based mapping to generate a spatial map of the corridor, which was then integrated into Unity to create a corresponding 3D environment. Using localization data, the real robot and its virtual counterpart in Unity were accurately synchronized.
A human pose detection algorithm running on the robot detected nearby people. When a person was detected, their position was accurately estimated and visualized in real time within the Unity 3D environment, enabling precise human-robot spatial awareness.
International Seminar Presentation
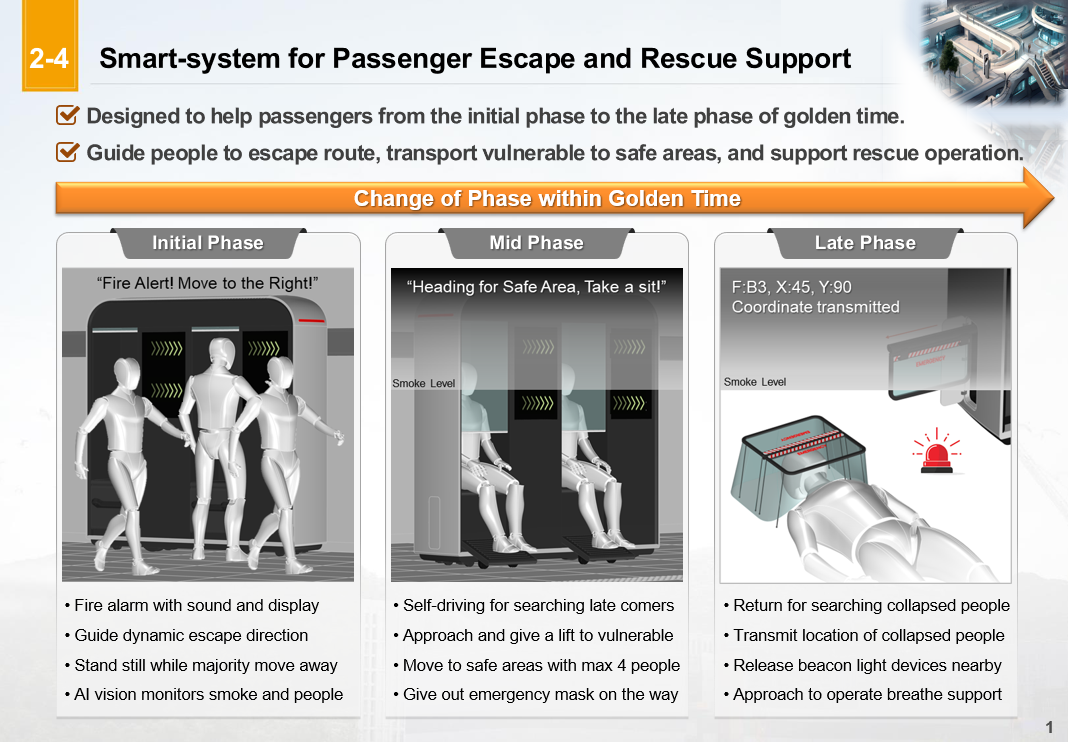
Research outcomes were presented at an international seminar, showcasing the system's capabilities for disaster-aware navigation and real-time digital twin synchronization.
Patents
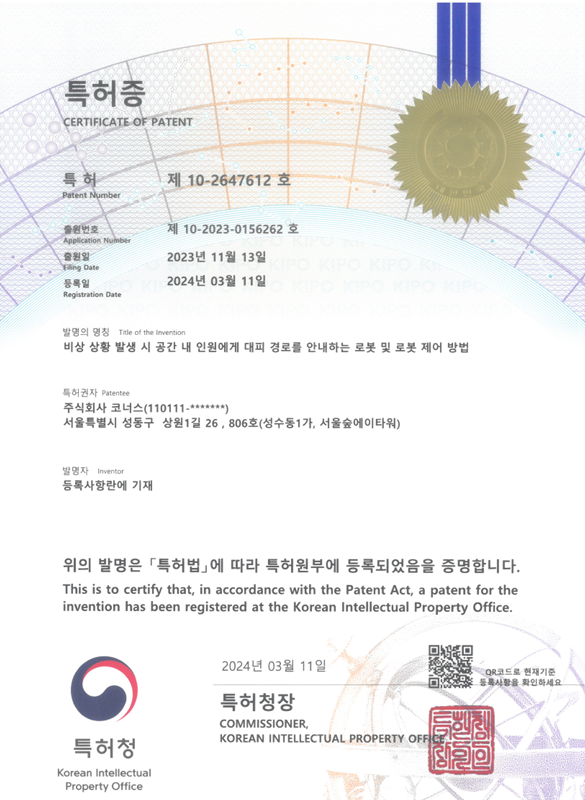
Robot for Guiding Evacuation Route for Persons in the Space in the Event of Emergency and Method for Controlling the Same
비상 상황 발생 시 공간 내 인원에게 대피 경로를 안내하는 로봇 및 로봇 제어 방법
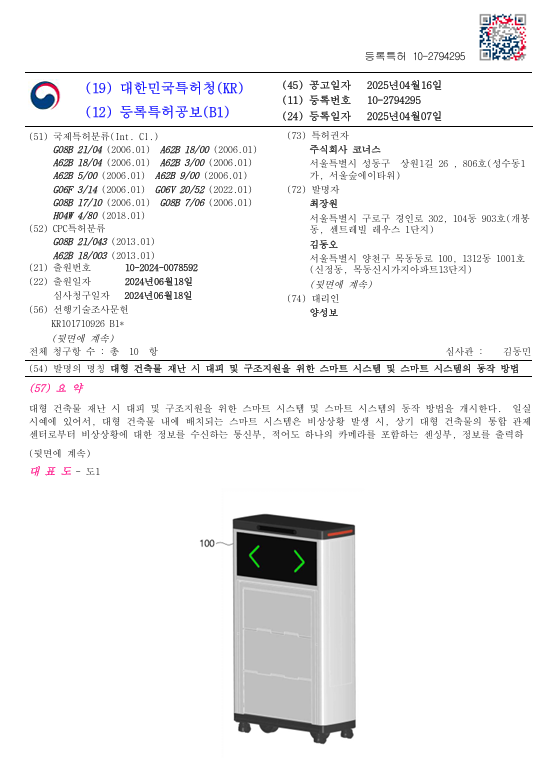
Smart System and Operation Method for Evacuation and Rescue Support in Case of Large Building Disaster
대형 건축물 재난 시 대피 및 구조지원을 위한 스마트 시스템 및 스마트 시스템의 동작 방법